Identifying Human Grasp Properties During Robot-to-Human Handovers
TL;DRMesurer, avec les seuls capteurs de force et de mouvement du robot, la fermeté avec laquelle une personne saisit un objet lors d’une passation, pour savoir quand le lâcher.
Résumé
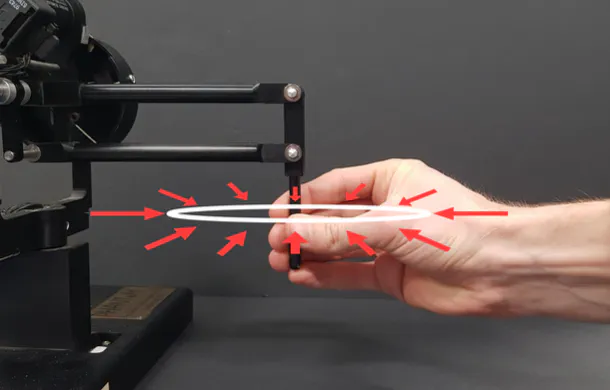
One of the most important challenges in HumanRobot Interaction (HRI) is the perception of the human state. When a robot physically engages with a human, such as during physical interaction and assistance, it is vital that the robot perceives as much information as possible about the human to properly guide its behavior. We examined the specific case of a robot handing a rigid object to a human and used only the robot’s force and motion sensors to determine when the human’s grasp was secure enough for the robot to safely release the object. From biomechanical reasoning, we assumed that safer grasps are stiffer grasps. We commanded our robot to impose small motions on the object being passed and measured the resulting force changes and used system identification techniques to measure and visualize changes in the human’s grasp stiffness. When subjects were instructed to grasp more tightly an object being passed, our robot could reliably detect increases in several measures of the multi-dimensional stiffness of the human’s grasp. Our technique also enabled us to measure the increases in damping with tighter grasps. This preliminary work demonstrates promising value for active haptic perception during physical HRI.
← Publications