On identifying the non-linear dynamics of a hovercraft using an end-to-end deep learning approach
TL;DRApprendre, à partir de données, un modèle dynamique non linéaire inspiré de la physique d’un aéroglisseur à hélices de drone, assez précis pour le contrôler en boucle fermée.
Résumé
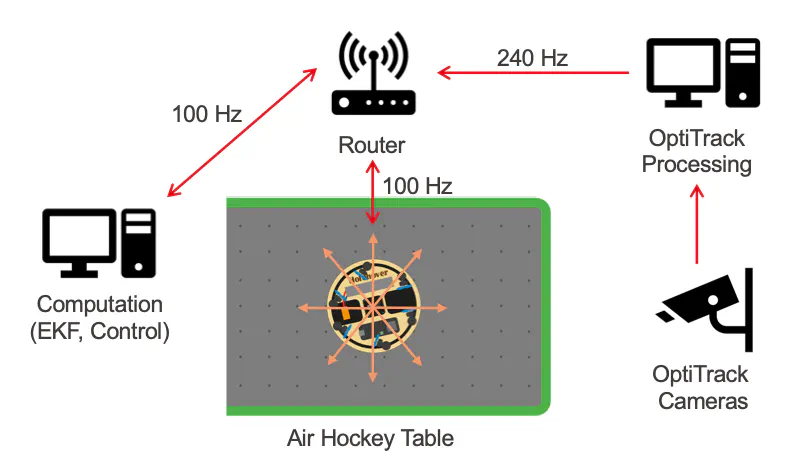
We present the identification of the non-linear dynamics of a novel hovercraft design, employing end-to-end deep learning techniques. Our experimental setup consists of a hovercraft propelled by racing drone propellers mounted on a lightweight foam base, allowing it to float and be controlled freely on an air hockey table. We learn parametrized physics-inspired nonlinear models directly from data trajectories, leveraging gradient-based optimization techniques prevalent in machine learning research. The chosen model structure allows us to control the position of the hovercraft precisely on the air hockey table. We then analyze the prediction performance and demonstrate the closed-loop control performance on the real system.
← Publications