Model Predictive Control (ME-425)
I was a teaching assistant for this Master course at EPFL.
About the course
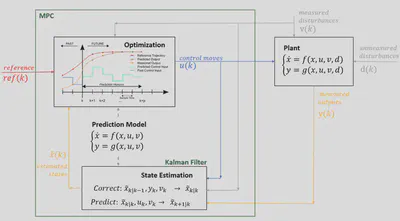
An introduction to the theory and practice of Model Predictive Control (MPC). MPC lets you specify time-domain objectives flexibly, optimise the performance of complex multivariable systems, and enforce constraints on the system’s behaviour explicitly.
Topics
- Convex optimisation and the optimal control theory MPC builds on
- Receding-horizon control of constrained linear systems
- Practical issues: tracking and offset-free control of constrained systems
- Theoretical properties: constraint satisfaction, invariant sets, stability of MPC
- An introduction to advanced topics in predictive control
- A simulation-based project giving hands-on experience with MPC
Course description in the EPFL coursebook · Figure: MathWorks